Priority Inversion 진단·예방 — Mars Pathfinder Lesson 추적
#한 줄 요약
“Priority Inversion = High task가 Low 잠금 자원 대기 + Medium에 차단됨” 1997년 Mars Pathfinder를 정지시켰던 bug입니다.
#시나리오
세 task가 시간축에서 어떻게 얽히는지 timeline으로 보면 한눈에 들어옵니다.
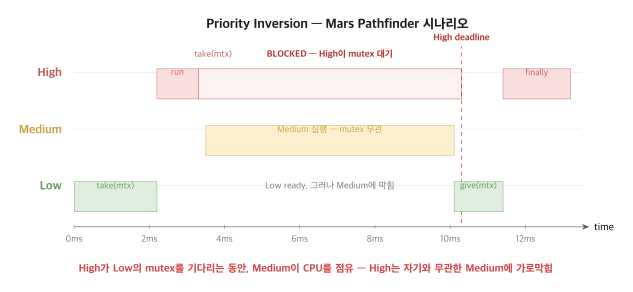
Task H (high) — periodic, 10 ms deadlineTask M (medium) — 일반 작업Task L (low) — log writer, mutex 보유
t=0: L take(mtx) → 시작t=1: H runnable → preempt L, H 실행t=2: H take(mtx) → block (L 보유 중)t=2: L ready, but M now CPU 점유 (L 못 가짐)t=10: M 계속 진행 → H deadline missMedium task는 lock과 무관한데도 결과적으로 high task를 블록합니다.
#Mars Pathfinder (1997)
NASA의 Sojourner rover 시스템:
- Bus management task (high)
- Comm task (medium) — frequent
- Weather task (low) — info_bus mutex 보유
순환:
- Weather 작업 중 → bus mgmt preempt
- Bus mgmt → mutex 시도 → block
- Comm 빈번 → CPU 점유
- Weather 미실행 → mutex 못 풀음
- Bus mgmt deadline miss → watchdog reset
매 며칠마다 system reset이 일어났습니다. 지구에서 원격으로 debug를 진행했고, priority inheritance를 활성화해 문제를 해결했습니다.
#Tony Hoare의 회상
"Priority Inheritance was implemented in VxWorks but disabled by default because of overhead concerns. We had to push the update."VxWorks의 selectPriorityInherit를 활성화해 문제를 해결했습니다.
#해결 1: Priority Inheritance (PI)
Low task가 mutex 보유 중 High task가 same mutex 대기:
- → Low task의 priority가 High 수준으로 boost
- → Medium이 preempt 못 함
- → Low 빨리 완료 → mutex give → High 진행
FreeRTOS PI mutex (xSemaphoreCreateMutex):
SemaphoreHandle_t mtx = xSemaphoreCreateMutex(); /* PI 자동 활성 */
xSemaphoreTake(mtx, portMAX_DELAY); /* High waiting → Low boost */critical();xSemaphoreGive(mtx); /* boost 복원 */POSIX:
pthread_mutexattr_setprotocol(&attr, PTHREAD_PRIO_INHERIT);pthread_mutex_init(&mtx, &attr);#Chain Inheritance
L1 보유 mtx_A, L2 보유 mtx_BL1 mtx_B 대기 → L2 boostH mtx_A 대기 → L1·L2 둘 다 boost체인 길이가 N이면 boost propagation과 ready-list 처리가 추가됩니다. 비용은 RTOS·port·체인 구조에 따라 측정해야 합니다.
자동차 ASIL-D에서는 chain depth를 제한합니다(보통 3 이하).
#해결 2: Priority Ceiling Protocol (PCP)
각 mutex에 ceiling priority를 미리 지정한다. ceiling = mutex를 사용할 가능성 있는 모든 task 중 최고 priority.
- Take 시 — task priority가 ceiling 수준으로 즉시 boost
- Give 시 — 원래 priority 복원
VxWorks와 INTEGRITY, 일부 µC/OS는 PCP를 지원합니다. 덕분에 WCET 분석이 훨씬 쉬워집니다.
#Immediate vs Original PCP
Immediate PCP (Sha 1990):
- Take 즉시 ceiling boost — 다른 mutex 대기 안 함
Original PCP:
- Ceiling만큼 boost되어 다른 lower priority task만 preempt 가능
Immediate와 Original 방식의 선택과 지원 여부는 RTOS 구현마다 다릅니다. 둘의 차이와 실제 지원 범위를 문서와 소스로 확인합니다.
#해결 3: Priority Ceiling Emulation (PCE)
Linux PREEMPT_RT의 mutex/priority protocol 지원은 kernel API와 설정에 따라 확인해야 하며, robust mutex와 priority ceiling을 같은 기능으로 간주하면 안 됩니다.
pthread_mutexattr_setprotocol(&attr, PTHREAD_PRIO_PROTECT);pthread_mutexattr_setprioceiling(&attr, 90);pthread_mutex_init(&mtx, &attr);Take 시점에 ceiling인 90으로 boost되어 우선순위가 자동으로 통제됩니다.
#진단 — Tracealyzer / SystemView
Trace 화면에서는 다음과 같이 확인할 수 있습니다.
- Task L이 “running” 상태로 priority boost와 함께 표시됩니다.
- Mutex가 L에 의해 잡혀 있다고 보입니다.
- Task H는 “blocked on mutex” 상태로 표시됩니다.
이렇게 하면 priority inversion을 직접 시각적으로 확인할 수 있습니다.
/* Debug — boost 횟수 측정 */struct mutex_stats { uint32_t boost_count; uint32_t max_boost_ms;};#ISR과 Priority Inversion
ISR이 H가 잡고 있는 mutex를 만나면 ISR에는 priority 개념이 없으므로 단순 block이 아니라 ISR-blocked-task 상황이 된다. 일반적으로 ISR은 mutex를 잡지 않는다.
ISR과 task 사이에는 semaphore(signaling)를 씁니다. Mutex는 task 간에만 사용합니다.
#예방 — Design Rule
- Short critical section을 μs 단위로 유지합니다.
- Sleep이나 IO 중에는 mutex를 잡지 않습니다.
- Lock ordering으로 deadlock과 chain inheritance를 제한합니다.
- PI mutex를 사용합니다(해당 RTOS의 mutex 구현과 설정 확인).
/* 회피 */xSemaphoreTake(&mtx, portMAX_DELAY);read_file(); /* ← seconds */xSemaphoreGive(&mtx);
/* Good */read_file();xSemaphoreTake(&mtx, portMAX_DELAY);update_var();xSemaphoreGive(&mtx);#Automotive — Lock 사용 자제
ASIL-D ECU:
- Mutex 자제, double buffer 또는 lock-free
- 사용 시 Immediate PCP + WCET 분석
- 일부 코드는 mutex 자체 금지
자동차에서는 예측 가능성이 throughput보다 우선합니다.
#Boeing 787 Bug
2015 — 787 시스템:
- 248일 후 RTOS counter overflow
- → priority inversion-like 상태로 fail
테스트되지 않은 long-run path는 WCET 분석에 반드시 포함해야 합니다. 단기 테스트만으로는 잡히지 않습니다.
#WCET 분석
Task H budget: 예시값 — 시스템 요구사항으로 산정Mutex hold worst case (Low): 측정·분석 필요Inheritance chain depth: 실제 lock graph로 산정Total worst case wait: WCET·스케줄링 분석 필요
H의 deadline 충족 여부는 측정된 WCET와 모든 blocking 항을 합산해 판단aiT와 Bound-T 같은 정적 WCET 도구를 활용합니다. 자동차와 항공 분야의 표준입니다.
#자주 하는 실수
⚠️ Non-PI mutex 사용
SemaphoreHandle_t mtx = xSemaphoreCreateBinary(); /* ← PI 없음 — semaphore */대신 xSemaphoreCreateMutex를 써야 PI가 자동으로 동작합니다.
⚠️ Long task in mutex
xSemaphoreTake(mtx, ...);http_request(); /* seconds — high task block */xSemaphoreGive(mtx);이때는 데이터를 미리 fetch해 두고 critical section을 짧게 유지해야 합니다.
⚠️ ISR이 mutex 사용
ISR: xSemaphoreTake(mtx, 0); /* ✗ */ISR에서는 mutex 대신 semaphore를 써야 합니다.
⚠️ Priority 계층 잘못 설계
Task H priority 5Task M priority 5 /* ← same priority → preempt 없음, FIFO */이런 경우에는 priority를 명확히 다르게 지정해야 합니다.
#정리
- Priority Inversion은 Low가 보유 + Medium이 preempt = High가 block되는 상황입니다.
- Mars Pathfinder는 1997년에 원격 patch로 해결했습니다.
- PI mutex는 보유자 priority를 동적으로 boost합니다.
- PCP는 컴파일 타임 ceiling을 활용해 더 단순한 분석이 가능합니다.
- Chain inheritance는 depth 제한이 필요합니다.
- ASIL-D에서는 lock 자체를 자제하고 double buffer를 선호합니다.
다음 편은 Memory Barrier입니다.
#관련 항목
Modern Embedded Recipes · 73 of 152
- 1 Modern Embedded Recipes — 모던 임베디드 실전 레시피 시리즈 소개
- 2 디지털 신호 기초 — Voltage Level·Edge·Setup/Hold 분석
- 3 임베디드 클럭과 타이밍 — Skew·Jitter·PLL·MMCM 분석
- 4 GPIO 내부 구조 분해 — Push-Pull·Open-Drain·Schmitt Trigger
- 5 UART 하드웨어 동작 분석 — Baud Rate·Framing·FIFO
- 6 SPI 하드웨어 분석 — Clock Mode·MOSI/MISO·Chip Select
- 7 I2C 하드웨어 분석 — Open-Drain·Clock Stretching·Arbitration
- 8 ADC 동작 원리 — SAR·Sigma-Delta·Pipelined 비교
- 9 DAC 동작 원리 — R-2R Ladder·Sigma-Delta·Settling Time
- 10 PWM 신호 생성 분석 — Duty·Frequency·Dead Time·Center-Aligned
- 11 CAN 버스 전기적 특성 — Differential·Termination·Dominant/Recessive
- 12 RS-485·RS-422 차동 신호 분석 — Termination·Biasing·Topology
- 13 LVDS 차동 신호 분석 — Common-Mode·Impedance·Eye Pattern
- 14 ARM Cortex-M 시리즈 비교 — M0·M3·M4·M7·M33·M55 분석
- 15 ARM Cortex-A 시리즈 비교 — A53·A55·A72·A78·X1 분석
- 16 ARM 레지스터 구조 분석 — R0~R15·CPSR·SPSR·Banked Registers
- 17 Cortex-M 예외 처리 — Vector Table·NVIC·Tail-Chaining 추적
- 18 ARM 메모리 맵 분석 — Normal·Device·Strongly-Ordered Region
- 19 ARM L1·L2 캐시 분석 — Set Associative·Inclusive·Maintenance
- 20 ARM MPU 활용 — Region·Attribute·Privilege Separation
- 21 ARM MMU 기초 분석 — Translation Table·TLB·ASID
- 22 ARM TrustZone-M 기초 — Secure/Non-Secure·NSC·MPC
- 23 ARM Memory Barrier 실전 — DMB·DSB·ISB·DMA·MMIO
- 24 임베디드 크로스 컴파일러 분석 — GCC·Clang·Sysroot 구성
- 25 C 컴파일 4단계 — Preprocess·Compile·Assemble·Link 추적
- 26 ELF 파일 구조 분석 — Section·Segment·Symbol Table·DWARF
- 27 링커 스크립트 기초 — SECTIONS·MEMORY·entry point
- 28 링커 스크립트 고급 — Overlay·BSS·init_array·LMA/VMA
- 29 임베디드 스타트업 코드 분석 — Reset_Handler·Vector Table·SystemInit
- 30 C 런타임 crt0 분석 — Stack·BSS Zero·Data Copy·atexit
- 31 임베디드 메모리 레이아웃 — .text·.rodata·.data·.bss·.heap·.stack
- 32 임베디드 컴파일러 최적화 분석 — -O0~-O3·-Os·-LTO 비교
- 33 Map 파일 분석 — Symbol·Section·Size 추적으로 코드 크기 진단
- 34 Make·CMake 크로스 컴파일 — Toolchain File·Sysroot 통합
- 35 임베디드 Bootloader 체인 — BootROM·SPL·U-Boot·Kernel·Secure Boot
- 36 첫 bare-metal 프로그램 작성 — Linker·Startup·main의 최소 구성
- 37 MMIO 레지스터 직접 접근 — volatile·Memory Map·Aliasing 분석
- 38 GPIO 드라이버 직접 구현 — STM32 HAL 없이 레지스터로
- 39 임베디드 클럭 설정 분석 — HSE·PLL·SYSCLK·AHB/APB 분주
- 40 Cortex-M 인터럽트 핸들링 — NVIC·Priority·Vector·EXTI
- 41 SysTick 타이머 활용 — 24-bit Counter·1ms Tick·delay 구현
- 42 UART 드라이버 구현 — polling·interrupt·DMA 3가지 방식 비교
- 43 SPI 드라이버 구현 — Master·Slave·CRC·DMA
- 44 I2C 드라이버 구현 — Master·7-bit/10-bit·Clock Stretching 처리
- 45 임베디드 DMA 기초 — Memory-to-Memory·Peripheral·Circular Mode
- 46 저전력 모드 분석 — Sleep·Stop·Standby·Wake-up Source
- 47 IWDG·WWDG 워치독 구현 — Independent vs Window 비교
- 48 임베디드 Flash 프로그래밍 — Erase·Program·Read While Write
- 49 DDR 초기화 실패 진단 — Timing·Calibration·Walking Bit Test
- 50 PWM 출력 실전 — LED 밝기·모터 속도 제어
- 51 DC 모터 제어 — H-Bridge·PWM Duty·Encoder Feedback
- 52 스테퍼 모터 제어 — Full Step·Half Step·Microstepping
- 53 서보 모터 제어 — PWM 1ms~2ms·Closed Loop·PID
- 54 Character LCD 제어 — HD44780·4-bit Mode·Custom Char
- 55 SPI OLED 제어 — SSD1306·Frame Buffer·Page 단위 갱신
- 56 TFT 디스플레이 구동 — RGB565·FSMC·LTDC·DMA2D
- 57 환경 센서 활용 — BME280 온습압·SHT3x 비교
- 58 IMU 센서 활용 — MPU6050·BMI270·Sensor Fusion
- 59 CAN 통신 구현 — bxCAN·Filter·Mailbox·CAN-FD
- 60 USB Device 기초 — Descriptor·Enumeration·Endpoint·HID/CDC
- 61 Ethernet MAC+PHY 통합 — RMII·lwIP·DMA Descriptor
- 62 SD Card + FatFs 구현 — SPI/SDIO 모드·CSD/CID·Wear
- 63 RTC 활용 — Calendar·Alarm·Wake-up Timer·Backup Domain
- 64 RTOS 도입 결정 분석 — Super Loop vs RTOS 트레이드오프
- 65 RTOS Task 설계 패턴 — 우선순위·스택·State Machine
- 66 RTOS Scheduler 동작 분석 — Tick·Context Switch·Yield
- 67 RTOS Semaphore 활용 — Binary·Counting·ISR Give
- 68 RTOS Mutex 활용 — Recursive·Priority Inheritance 적용
- 69 RTOS Queue 활용 — By-Value·By-Reference·Timeout 패턴
- 70 RTOS Event Group 활용 — Bit Wait·Sync·Notify
- 71 RTOS Software Timer 활용 — One-shot·Auto-reload·Daemon Task
- 72 ISR-Safe API 설계 — Reentrant·Atomic·Defer 패턴
- 73 Priority Inversion 진단·예방 — Mars Pathfinder Lesson 추적
- 74 Timer Wheel 분석 — Hashed·Hierarchical·O(1) Tick
- 75 RTOS 디버깅 기법 — Tracealyzer·SystemView·Stack 추적
- 76 임베디드 Linux 부팅 흐름 분석 — BootROM·U-Boot·Kernel·init
- 77 U-Boot 활용 — bootcmd·env·tftp·boot.scr 분석
- 78 Device Tree 실전 — DTS·DTB·Overlay·Phandle 추적
- 79 Device Tree Overlay 적용 — Runtime fragment·dtoverlay
- 80 임베디드 커널 빌드 — defconfig·menuconfig·Image·zImage
- 81 커널 모듈 기초 — init/exit·Parameter·KBuild·DKMS
- 82 캐릭터 드라이버 작성 — file_operations·cdev·register_chrdev
- 83 Platform 드라이버 작성 — probe·remove·of_match·DT 바인딩
- 84 mmap 4가지 모드 — Anonymous·File·Shared·Huge Page
- 85 epoll 실전 — LT·ET·ONESHOT·EXCLUSIVE 비교
- 86 UIO·VFIO 분석 — User-Space Driver와 IOMMU 격리
- 87 sysfs·configfs 활용 — kobject 기반 User 인터페이스
- 88 IRQ Affinity 튜닝 — smp_affinity·isolcpus·irqbalance
- 89 루트 파일시스템 구축 — Buildroot 기초·Package·Toolchain
- 90 임베디드 동적 메모리 — malloc 위험·결정성·대안 분석
- 91 메모리 정렬과 패딩 분석 — Natural·Strict Alignment·Trap
- 92 Cache Line Alignment — alignas·Padding·SoA 적용
- 93 DMA-Friendly Allocator — dma_alloc_coherent·IOMMU·Pool
- 94 Zero-Copy Pipeline — DMA-BUF·sendfile·io_uring·splice
- 95 NUMA Memory Topology — numactl·numa_alloc·HBM 적용
- 96 SIMD 활용 분석 — Intrinsics·Auto-Vectorization·OpenMP SIMD
- 97 ARM NEON 심화 — Matrix Multiply·FFT·Image Filter 적용
- 98 임베디드 스택 분석 — high-water·overflow 탐지
- 99 임베디드 코드 크기 최적화 — -Os·LTO·Section Garbage Collection
- 100 임베디드 전력 최적화 — Sleep Mode·Clock Gating·DVFS
- 101 WCET 분석 기법 — Static·Measurement·Hybrid 방법론
- 102 Lock-Free Ring Buffer 구현 — SPSC·Power-of-2·Memory Order
- 103 Wait-Free Signaling — Atomic Flag·Sequence·Latest-Value
- 104 RCU (Read-Copy-Update) 기초 — Quiescent State·Grace Period
- 105 Hazard Pointer 분석 — Lock-Free Memory Reclamation
- 106 Compare-And-Swap 패턴 — Stack·Counter·Linked List 적용
- 107 Atomic Operation 비용 분석 — Fence·Cache Line·Contention
- 108 Spinlock vs Mutex 결정 가이드 — Context Switch·Hold Time
- 109 ABA 문제 회피 — Tagged Pointer·Hazard·Generation Counter
- 110 False Sharing 해결 — Cache Line Padding·SoA 적용
- 111 MPMC Queue 구현 — Multi-producer Multi-consumer Lock-Free
- 112 임베디드 디버깅 마인드셋 — 가설·격리·재현·이분탐색
- 113 JTAG·SWD 안 붙을 때 — 핀·전압·속도·세션 진단
- 114 GDB 원격 디버깅 — OpenOCD·J-Link·target remote 구성
- 115 Cortex-M 하드폴트 분석 — Stacked Frame·CFSR 읽기
- 116 UART 안 찍힐 때 — Bare-metal 체크리스트
- 117 임베디드 부팅 실패 진단 — 단계별 Isolation
- 118 인터럽트 누락·중복 진단 — Priority·Pending·Re-entry 추적
- 119 메모리 오버플로우·오염 진단 — Canary·MPU·Pattern 분석
- 120 타이밍·Race 진단 — Heisenbug 잡는 법
- 121 통신 프로토콜 분석 — Logic Analyzer와 Protocol Decoder
- 122 임베디드 로깅 시스템 설계 — 레벨·버퍼·SWO·Deferred
- 123 임베디드 포스트모템 분석 — Core Dump와 Field Crash
- 124 FPGA 기초 분석 — LUT·FF·BRAM·DSP 자원 구조
- 125 Vivado 사용법 — Project·Constraint·Synth·Impl·Bitstream
- 126 PCIe BAR 매핑 분석 — Config Space·Enumeration·MMIO 접근
- 127 AXI 인터페이스 — AXI4·AXI4-Lite·AXI-Stream 비교
- 128 Zynq PS-PL 통신 — GP·HP·ACP 인터페이스 선택
- 129 Mailbox Protocol 분석 — Host와 Accelerator를 잇는 Doorbell
- 130 Command Queue·Submission Queue — NVMe·XDMA 공통 패턴
- 131 DMA Completion 메커니즘 — Interrupt·Polling·Completion Ring
- 132 PCIe Streaming 분석 — BAR Type·MSI-X·Kernel Bypass
- 133 Vitis HLS 분석 — Pragma·Pipeline II·Dataflow 실전 감각
- 134 HLS 최적화 기법 — Pipeline·Unroll·Partition·Dataflow
- 135 Vitis AI 분석 — DPU·xmodel·VART
- 136 OpenCL on FPGA — Kernel·Channel·Burst Memory 분석
- 137 Intel Quartus 사용법 — Platform Designer·Nios II·HLS
- 138 Edge Inference 분석 — Cloud vs Edge·Latency·Privacy
- 139 NPU 아키텍처 분석 — Ethos·Hexagon·Systolic Array 비교
- 140 딥러닝 Quantization 분석 — PTQ·QAT·INT8·INT4·Calibration
- 141 TensorRT 분석 — ONNX→Engine·FP16·INT8·DLA·Multi-Stream
- 142 TFLite Micro 분석 — Op Resolver·Tensor Arena·Cortex-M
- 143 ONNX Runtime 분석 — Execution Provider와 Cross-Platform 배포
- 144 Edge Thermal Management — Throttling·DVFS·Fan Curve·Sustained
- 145 NVIDIA Jetson 분석 — Nano·Xavier·Orin·Thor·JetPack·DLA·VPI
- 146 Zero-Copy Camera Pipeline — V4L2·DMA-BUF·GPU Import·NPU 직결
- 147 온디바이스 LLM 추론 — llama.cpp·GGUF·MLX·KV Cache·NPU Backend
- 148 Cortex-M33 TF-M·TrustZone — Secure Firmware·PSA·MCUboot
- 149 Matter·Thread 분석 — IoT 통합 표준·Commissioning·Multi-Fabric
- 150 PCIe → CXL 진화 — 같은 PHY 위 cache-coherent 프로토콜 추가
- 151 QEMU CXL Type 3 디바이스 에뮬레이션 — 노트북에서 CXL 개발 환경 구축
- 152 Linux CXL 드라이버 분석 — cxl_pci·cxl_core·region·DAX
관련 글
Timer Wheel 분석 — Hashed·Hierarchical·O(1) Tick
Timer wheel 자료구조. Hashed wheel·hierarchical wheel·O(1) tick·Linux jiffies.
같은 시리즈에서 이어 읽기
RTOS 디버깅 기법 — Tracealyzer·SystemView·Stack 추적
Stack high-water mark, overflow hook, deadlock 탐지, heap 분석, trace 도구까지 RTOS 디버깅을 한 자리에 정리합니다.
같은 시리즈에서 이어 읽기
Priority Inversion 문제 — Mars Pathfinder 사례·Bounded vs Unbounded
고우선 task가 저우선 task 때문에 막힘. 1997 화성 탐사선 reset의 원인.
공통 태그 기반 추천